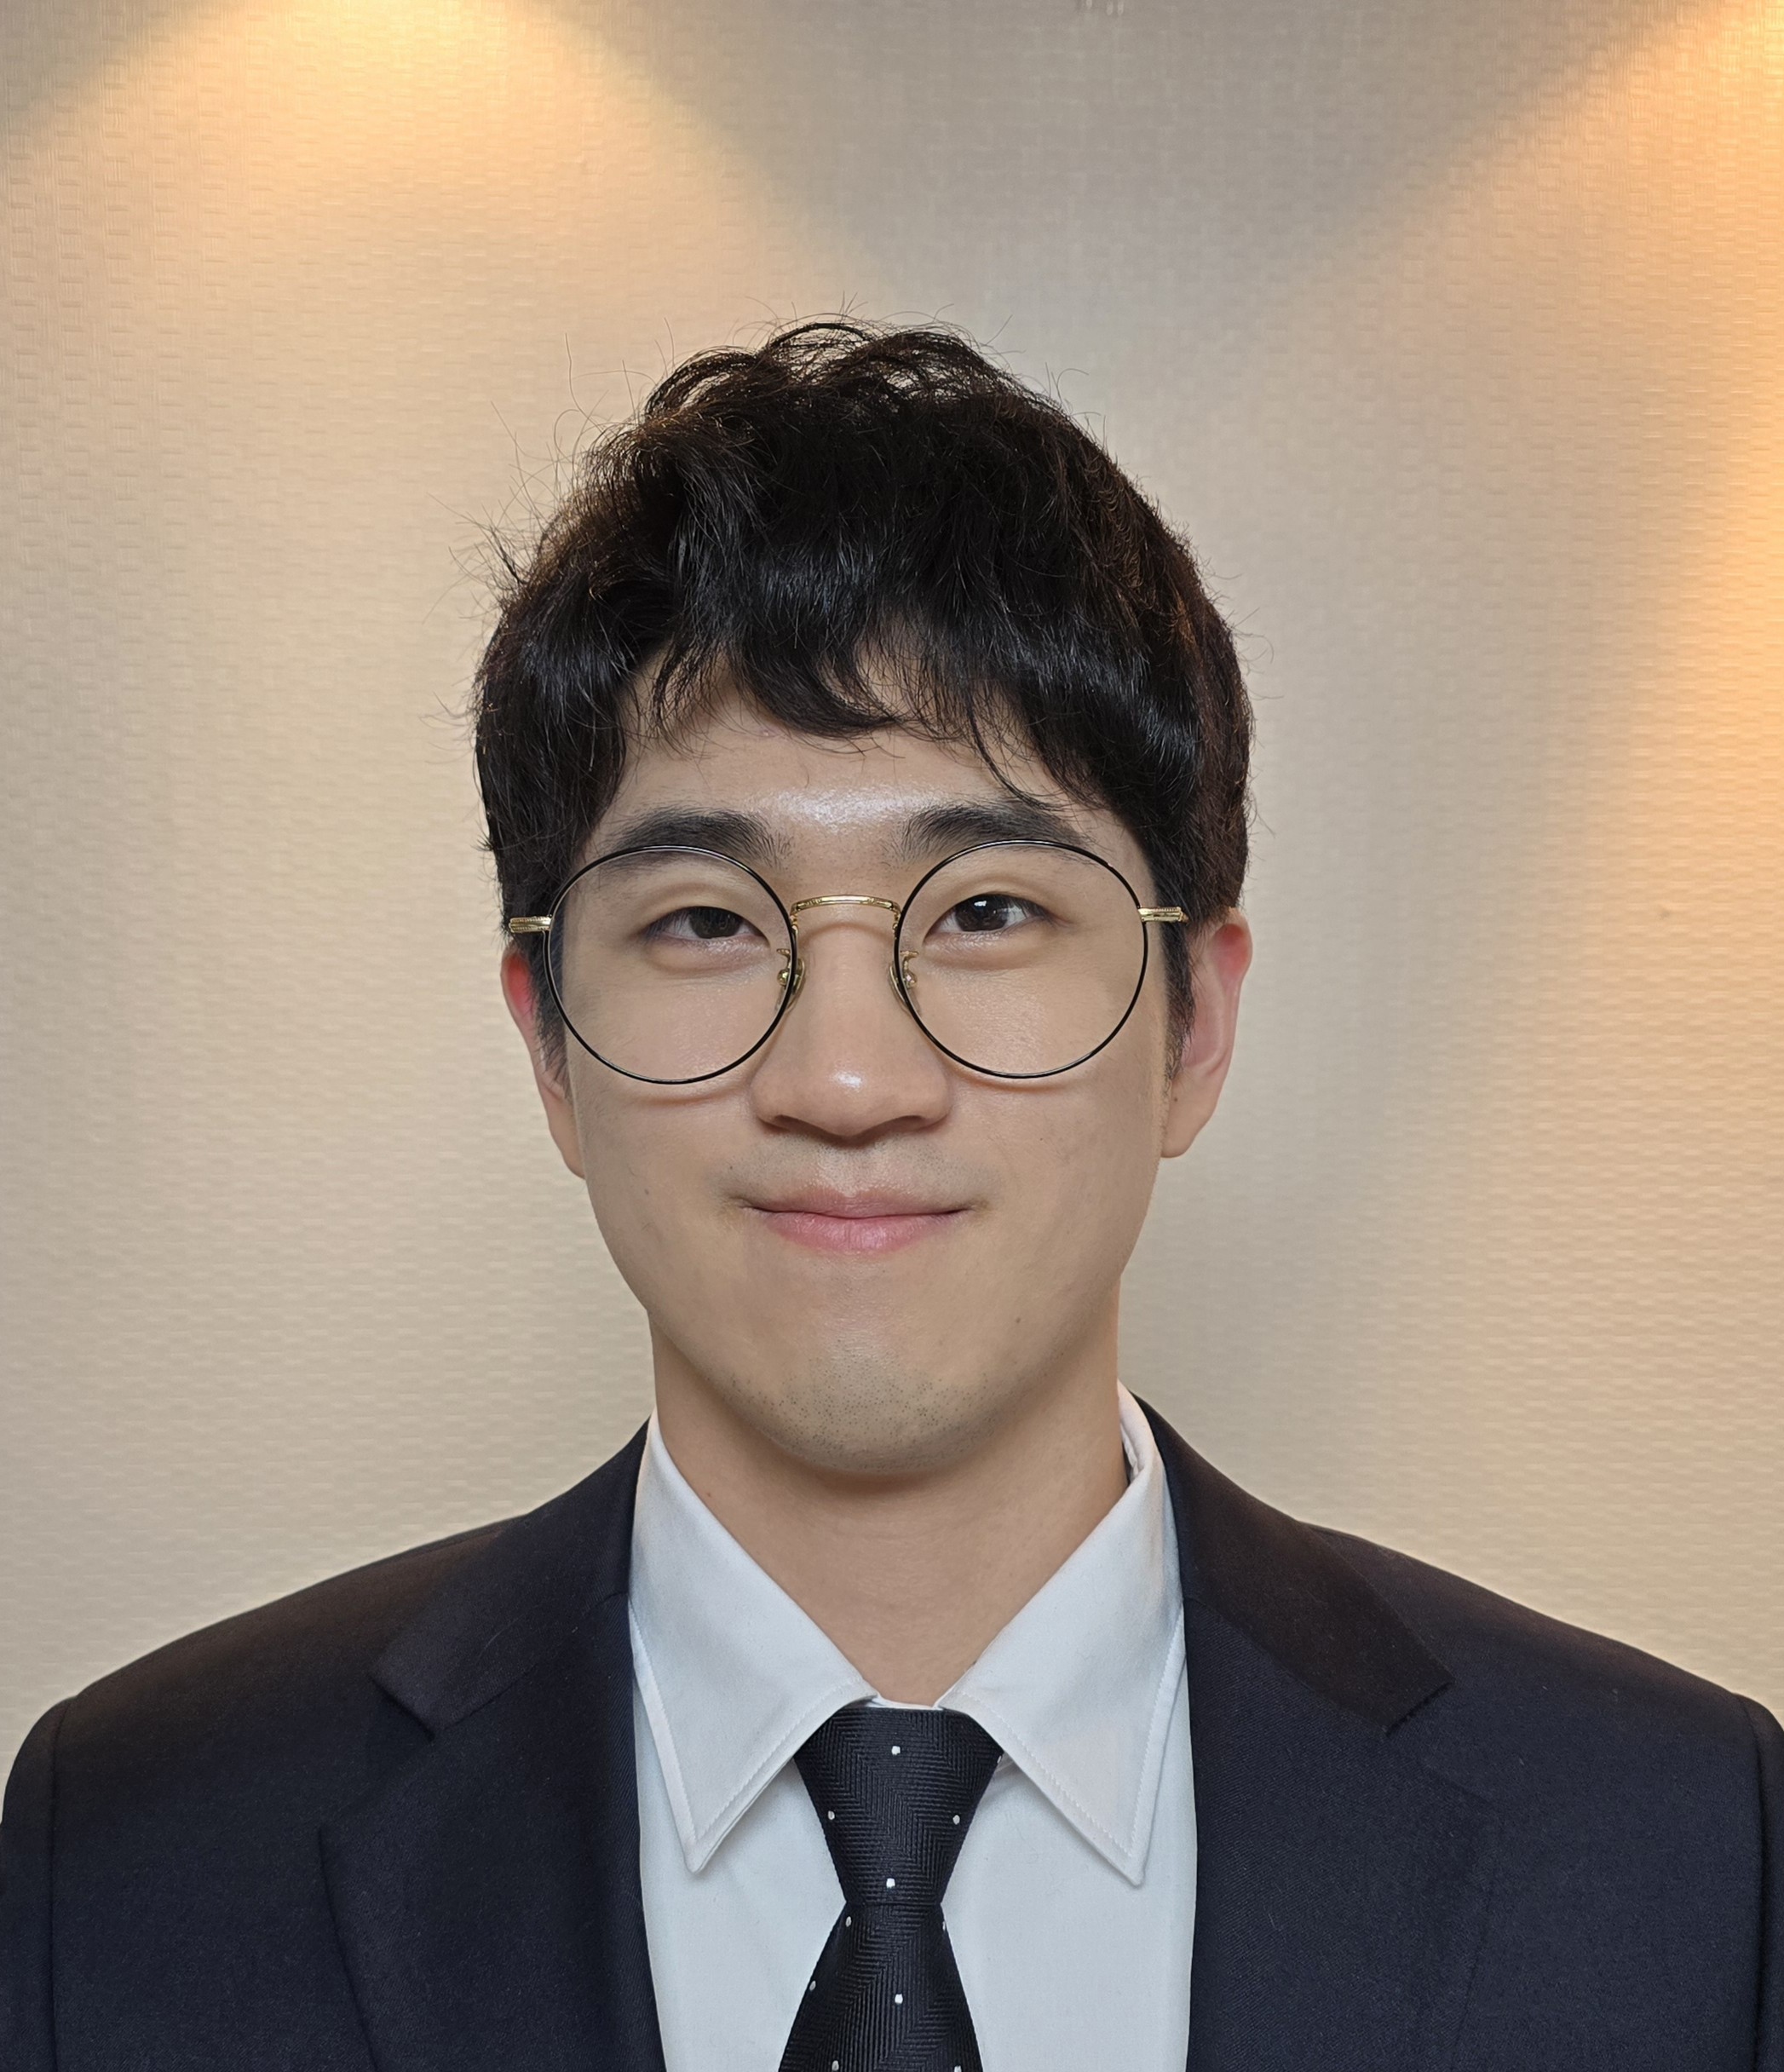
Haejoon Lee
PhD Candidate in Robotics, University of Michigan
I am a fourth-year Ph.D student at the DASC Lab, part of the Department of Robotics at the University of Michigan, Ann Arbor. I am advised by Professor Dimitra Panagou.
My research focuses on enabling autonomous multi-agent systems to operate safely and reliably in dynamic, uncertain, and adversarial environments. My research combines provable guarantees with scalable algorithms across resilient network design, distributed control, optimization, and learning, with a recent focus on diffusion-based planning for large robot teams. My long-term vision is to enable hundreds of robots to coordinate and make decisions online, efficiently and resiliently, in real-world environments.
Previously, I worked with Professor Nilanjan Chakraborty at Stony Brook University on multi-robot task allocation under uncertainties, and with Professor Tan H. Cao on multi-agent collision avoidance using Moreau's Sweeping Process. I earned my Bachelor's degree in Applied Math and Statistics from Stony Brook University.