Publications
Conferences
2026

Distributed Model-Based Diffusion For Scalable Multi-Robot Trajectory Optimization
submitted and under review


Fully Byzantine-Resilient Distributed Multi-Agent Q-Learning
2026 IEEE Conference on Decision and Control (CDC)
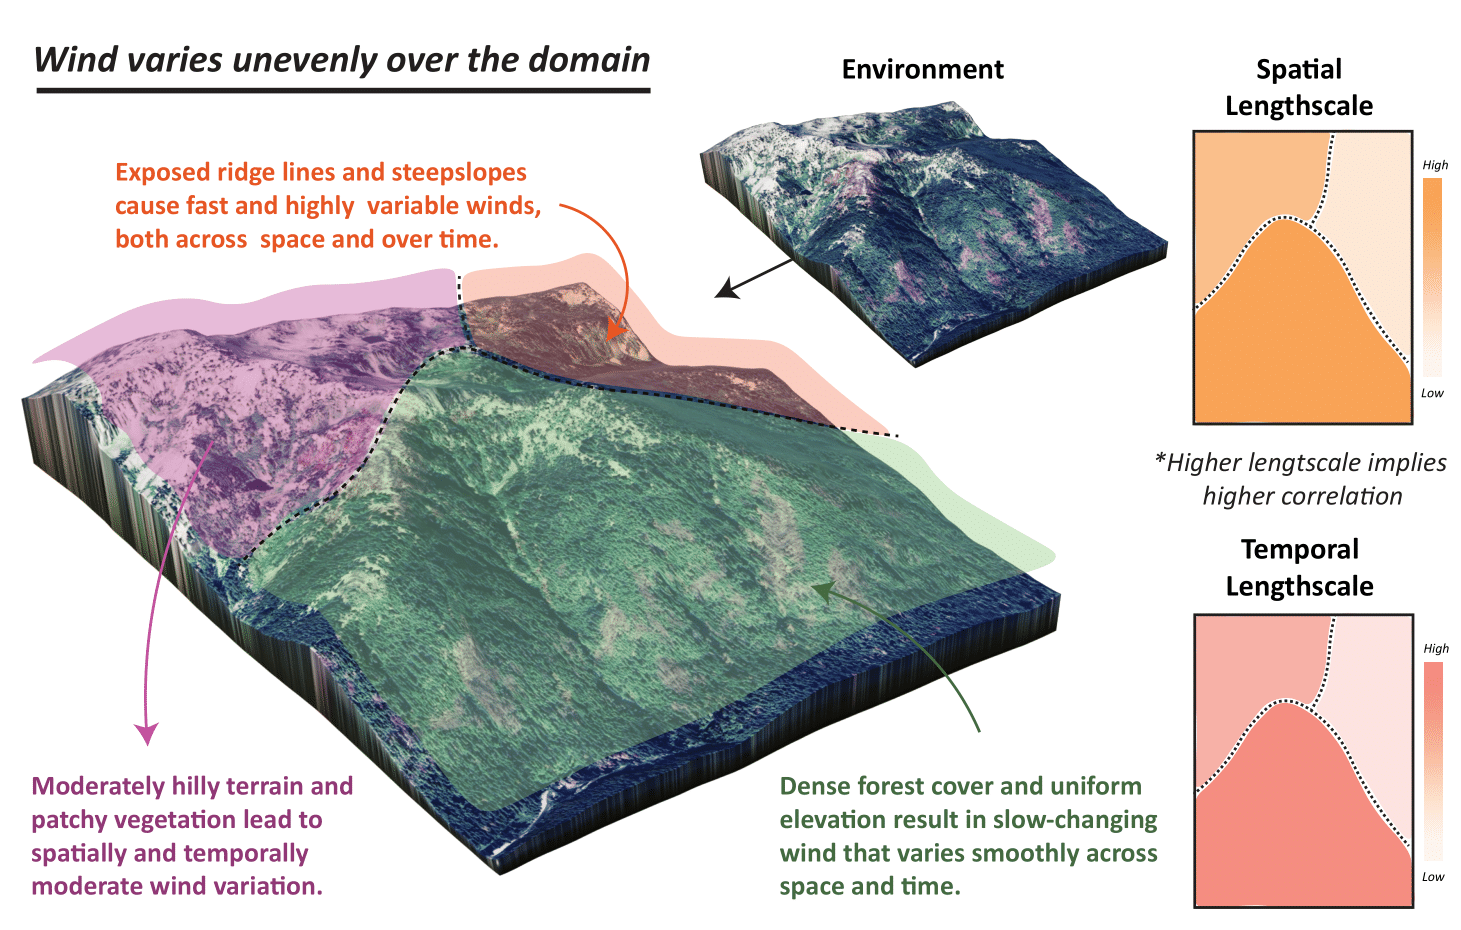
Multi-Robot Allocation for Information Gathering in Non-Uniform Spatiotemporal Environments
2026 IEEE American Control Conference (ACC)
2025
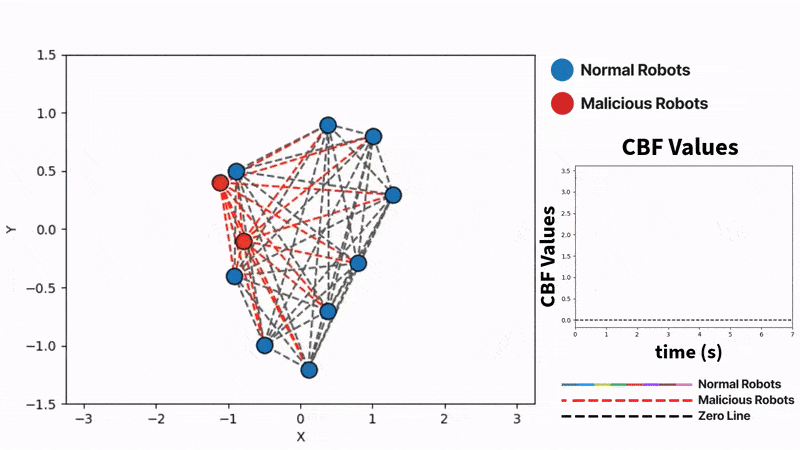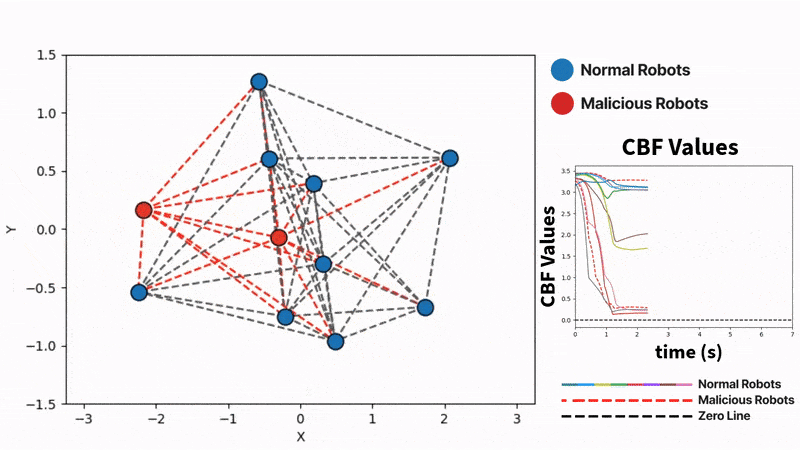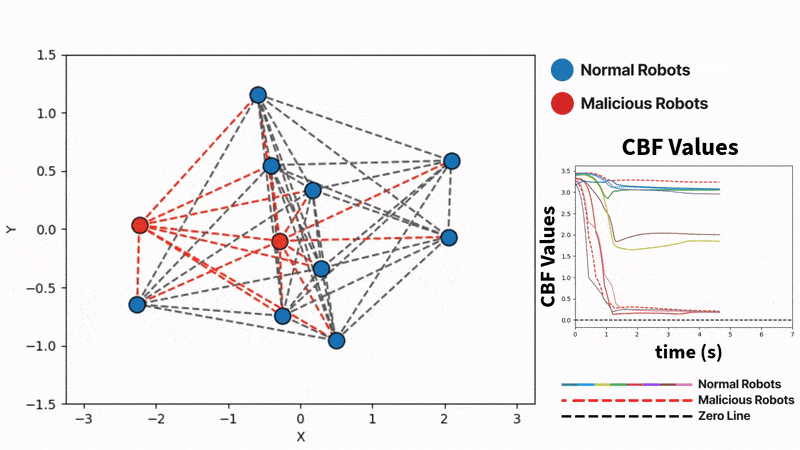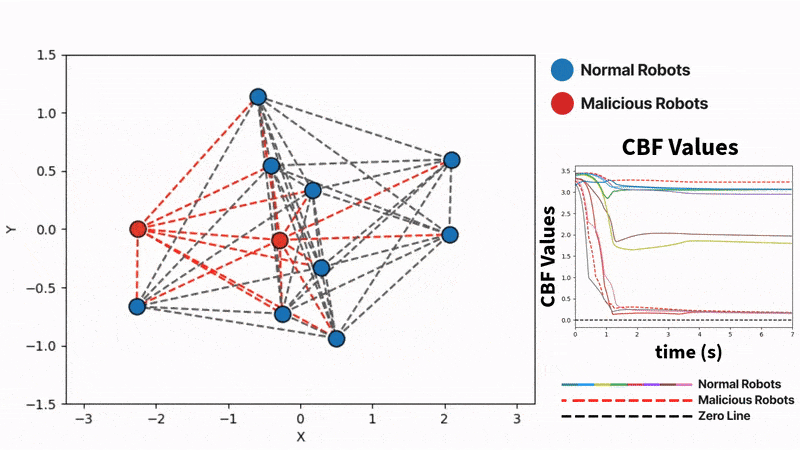
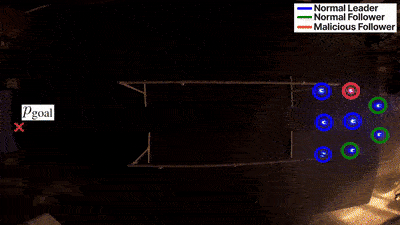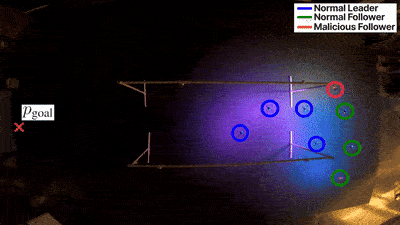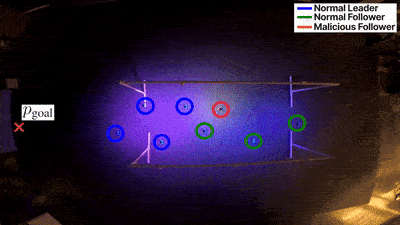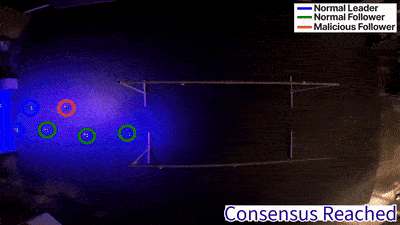
Maintaining Strong r-Robustness in Reconfigurable Multi-Robot Networks Using Control Barrier Functions
2025 IEEE International Conference on Robotics and Automation (ICRA)
2024
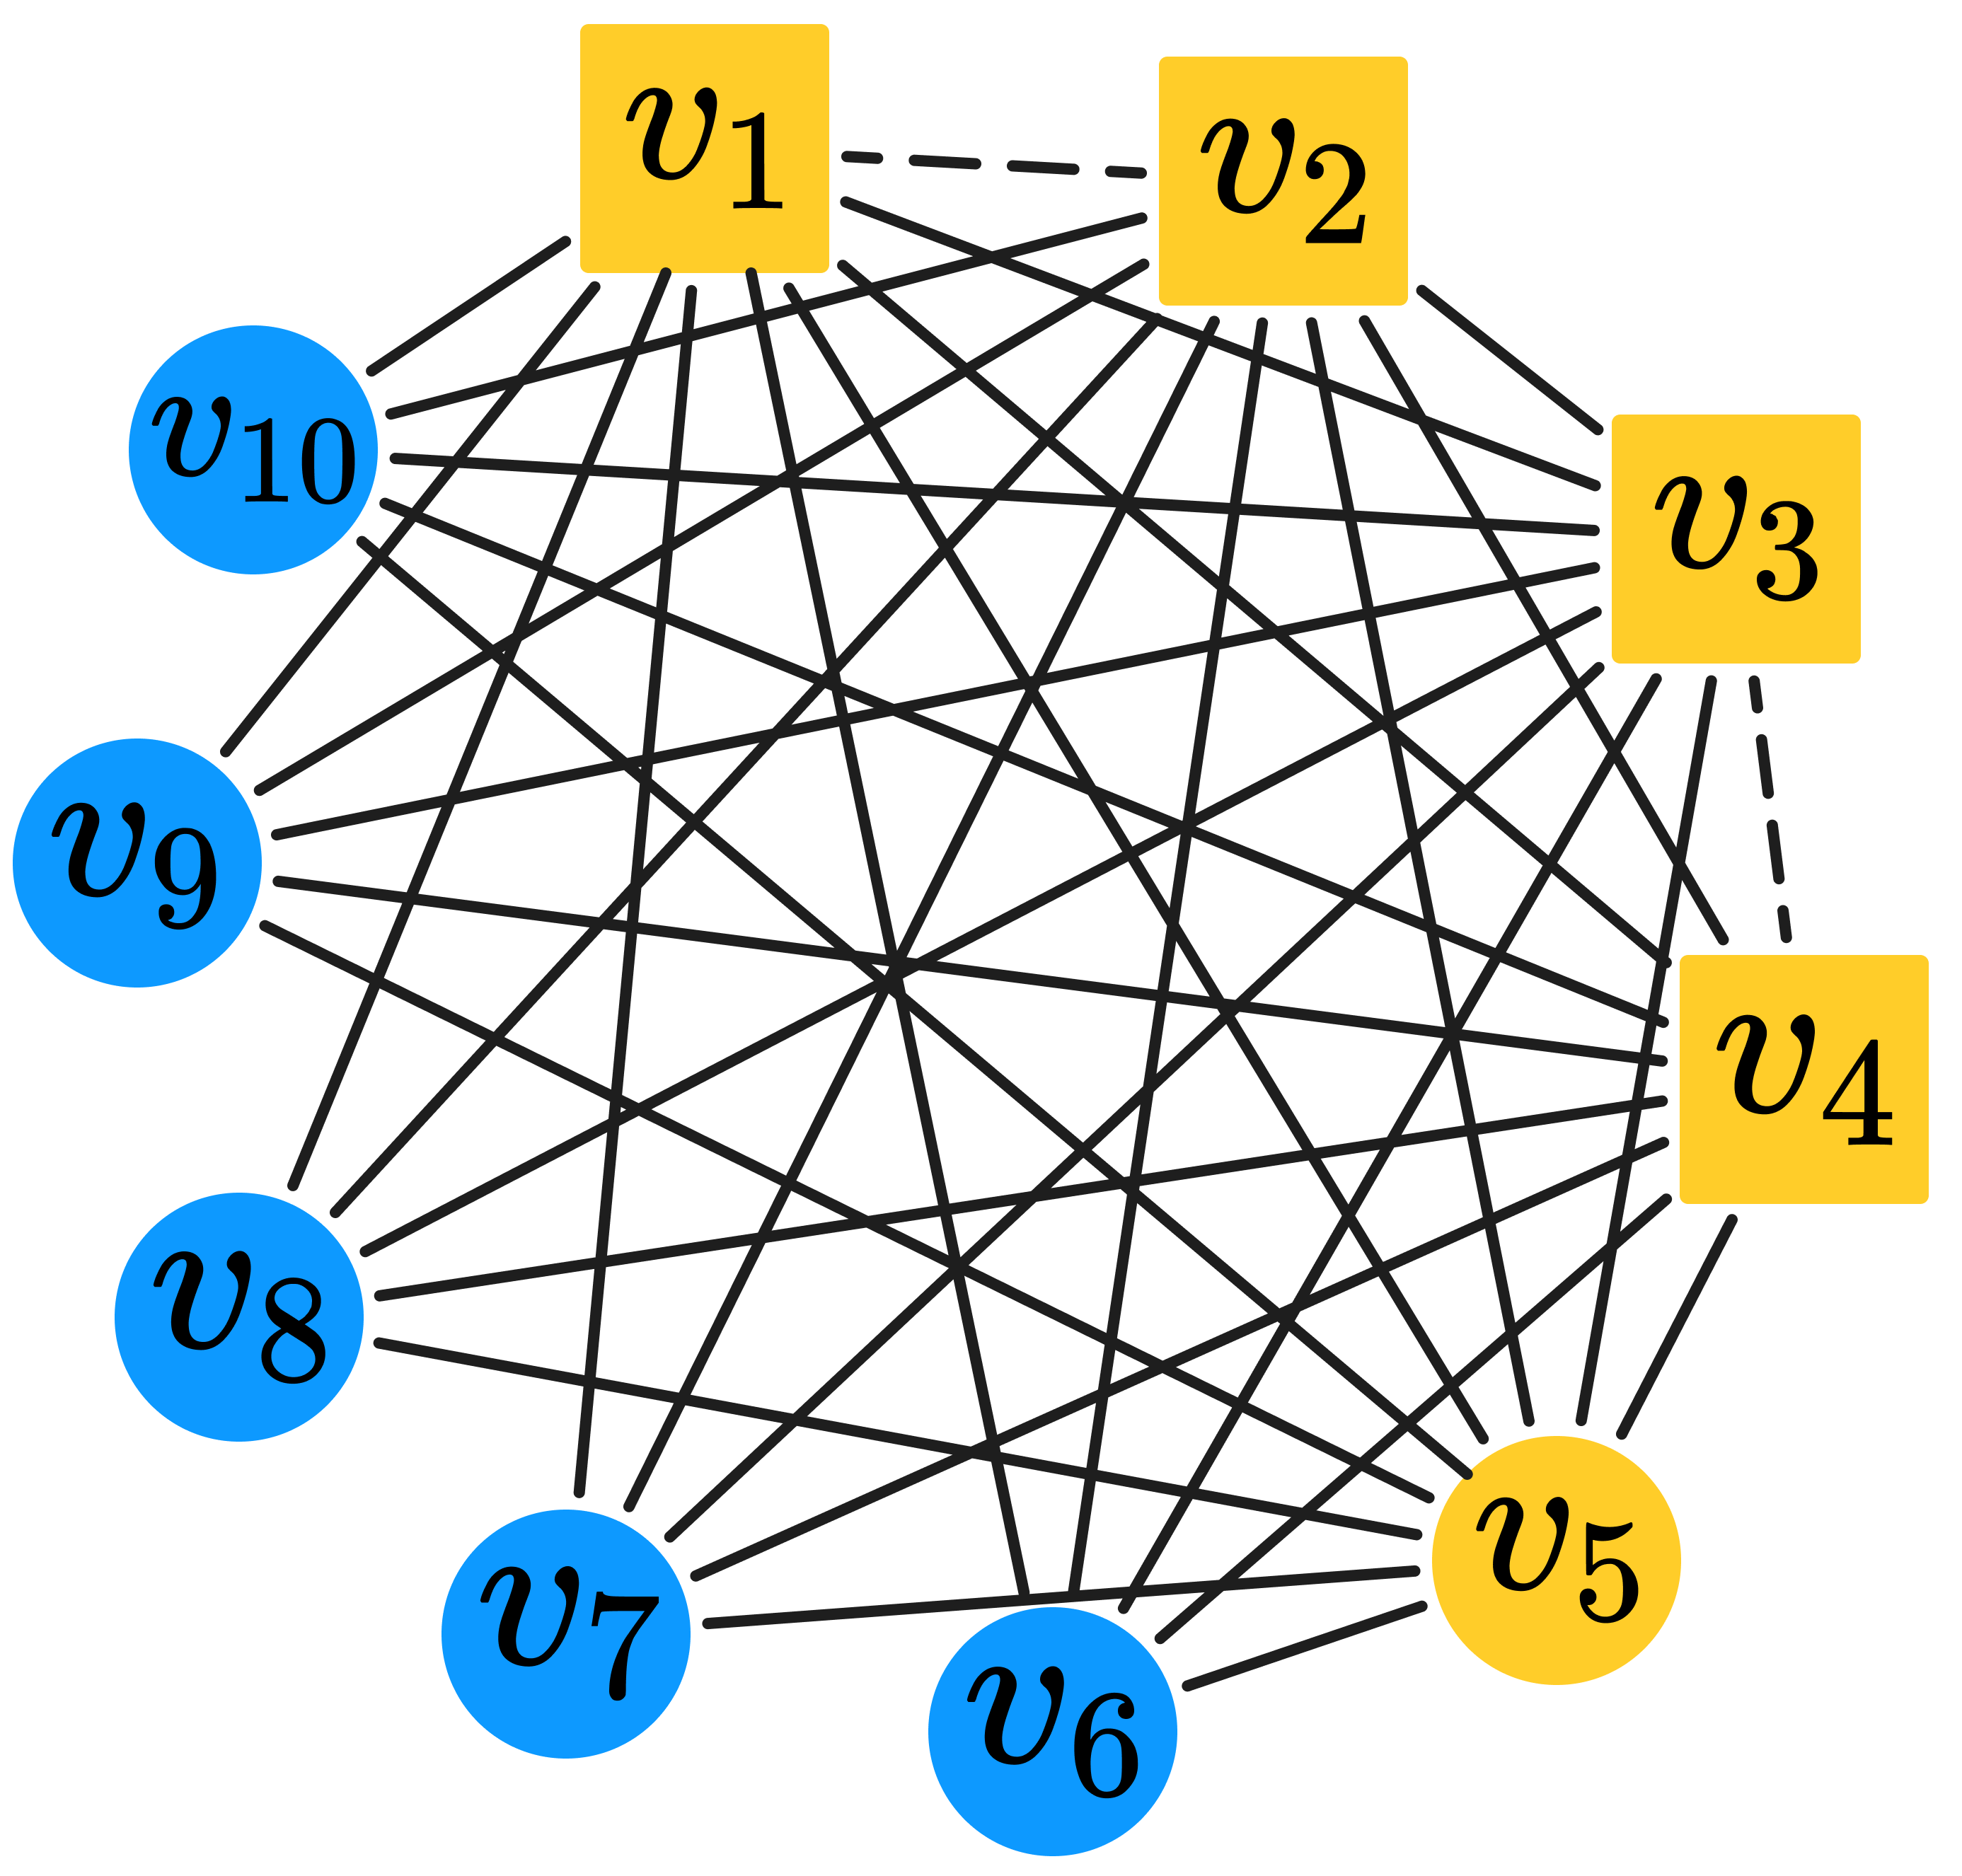
Construction of the Sparsest Maximally r-Robust Graphs
2024 IEEE Conference on Decision and Control (CDC)
Journals
2027
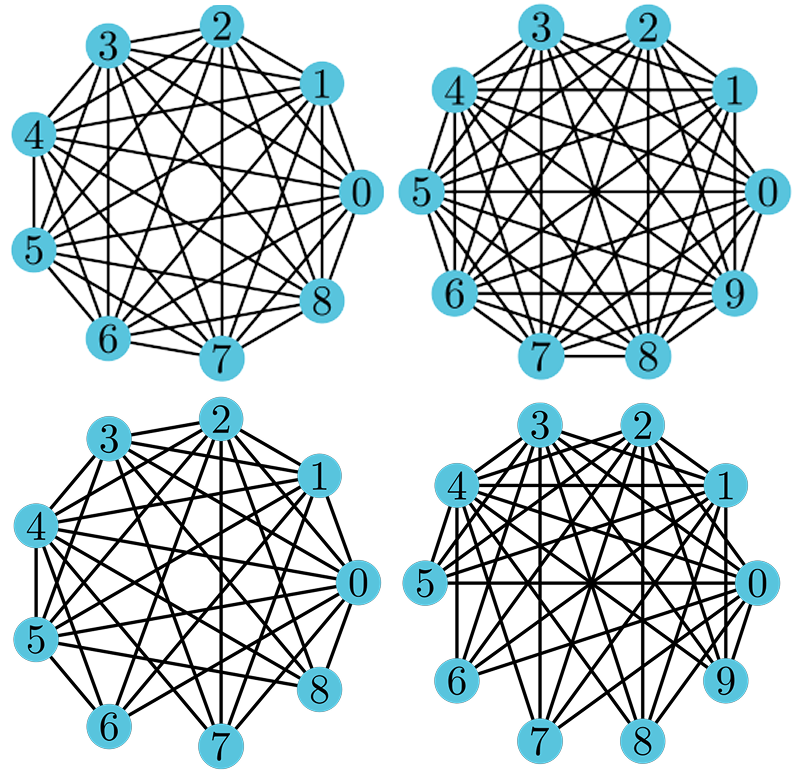
Minimal Construction of Graphs with Maximum Robustness
Transactions on Automatic Control (TAC) 2027
2026

Distributionally Robust Safety Under Arbitrary Uncertainties: A Safety Filtering Approach
IEEE Robotics and Automation Letters (RA-L) 2026

Feasibility Analysis and Constraint Selection in Optimization-Based Controllers
submitted and under review
2025
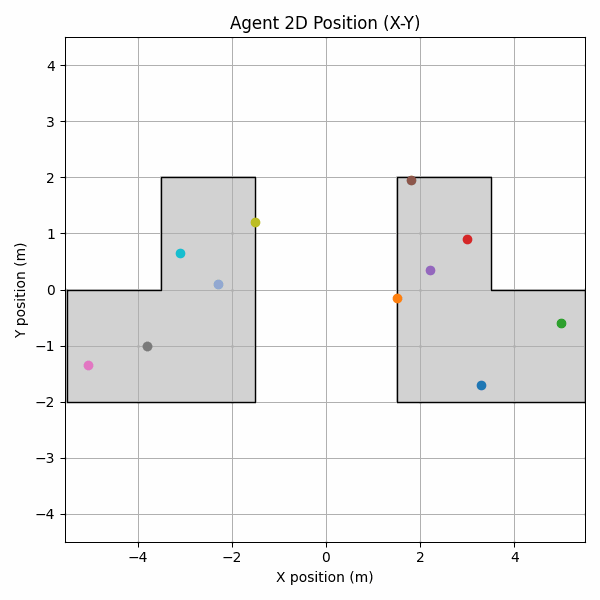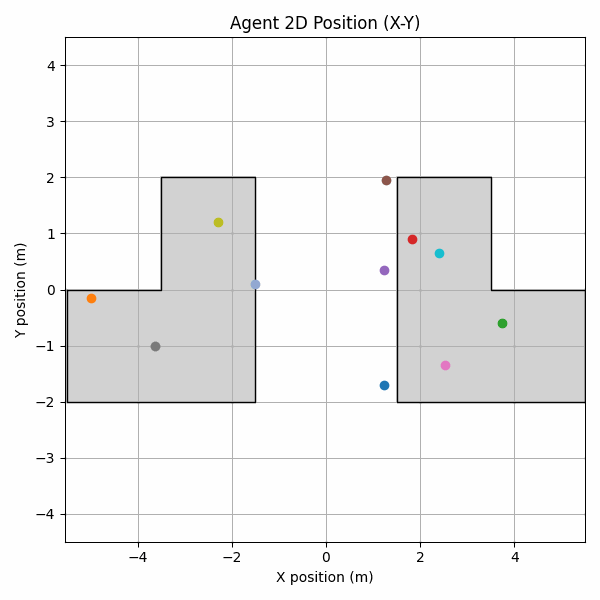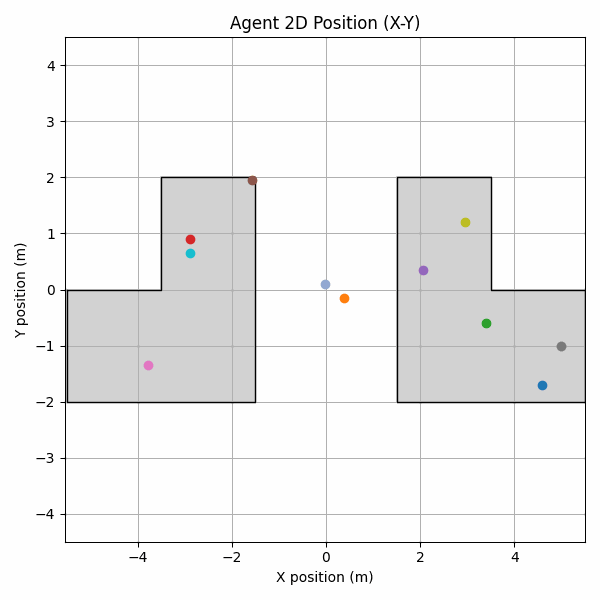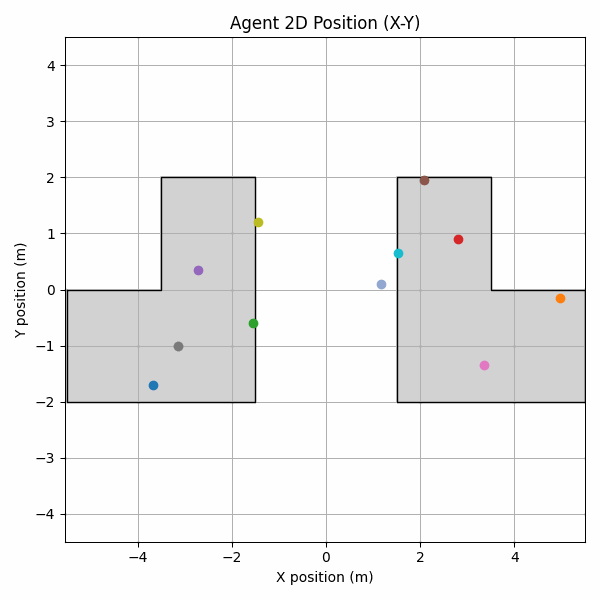
Combinatorial Control Barrier Functions: Nested Boolean and p-choose-r Compositions of Safety Constraints
2025 IEEE Control Systems Letters (L-CSS)